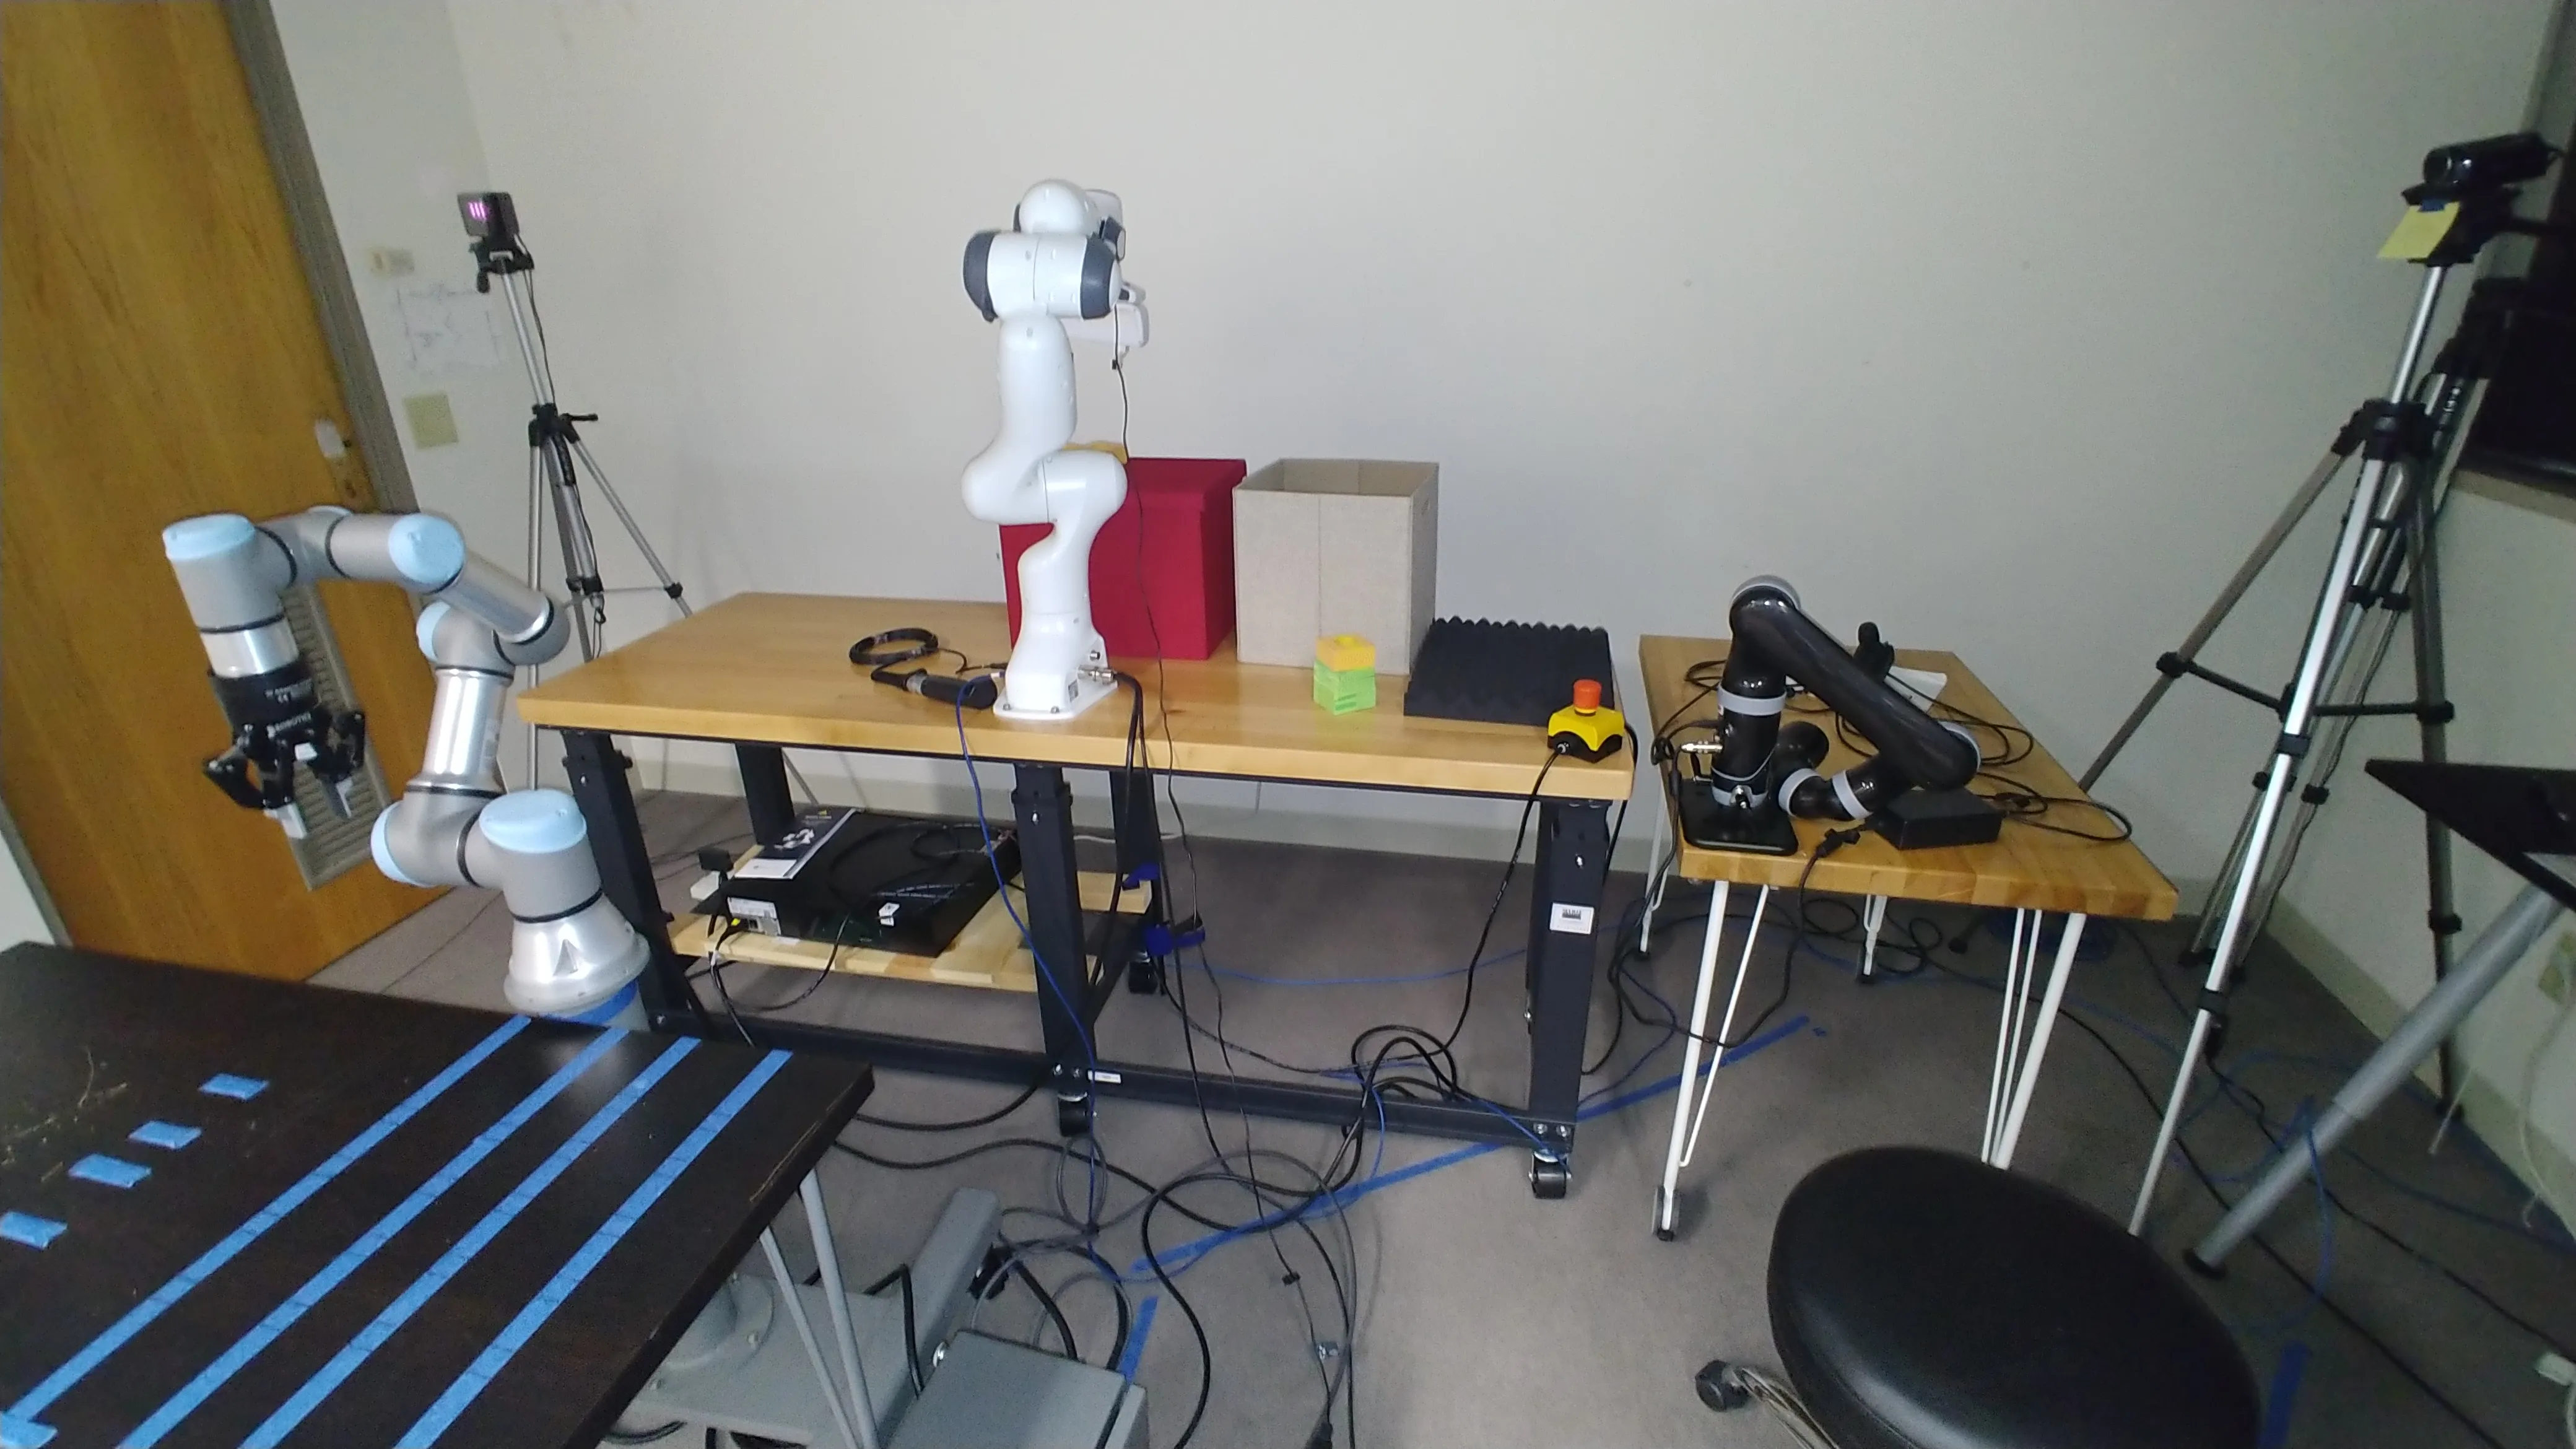
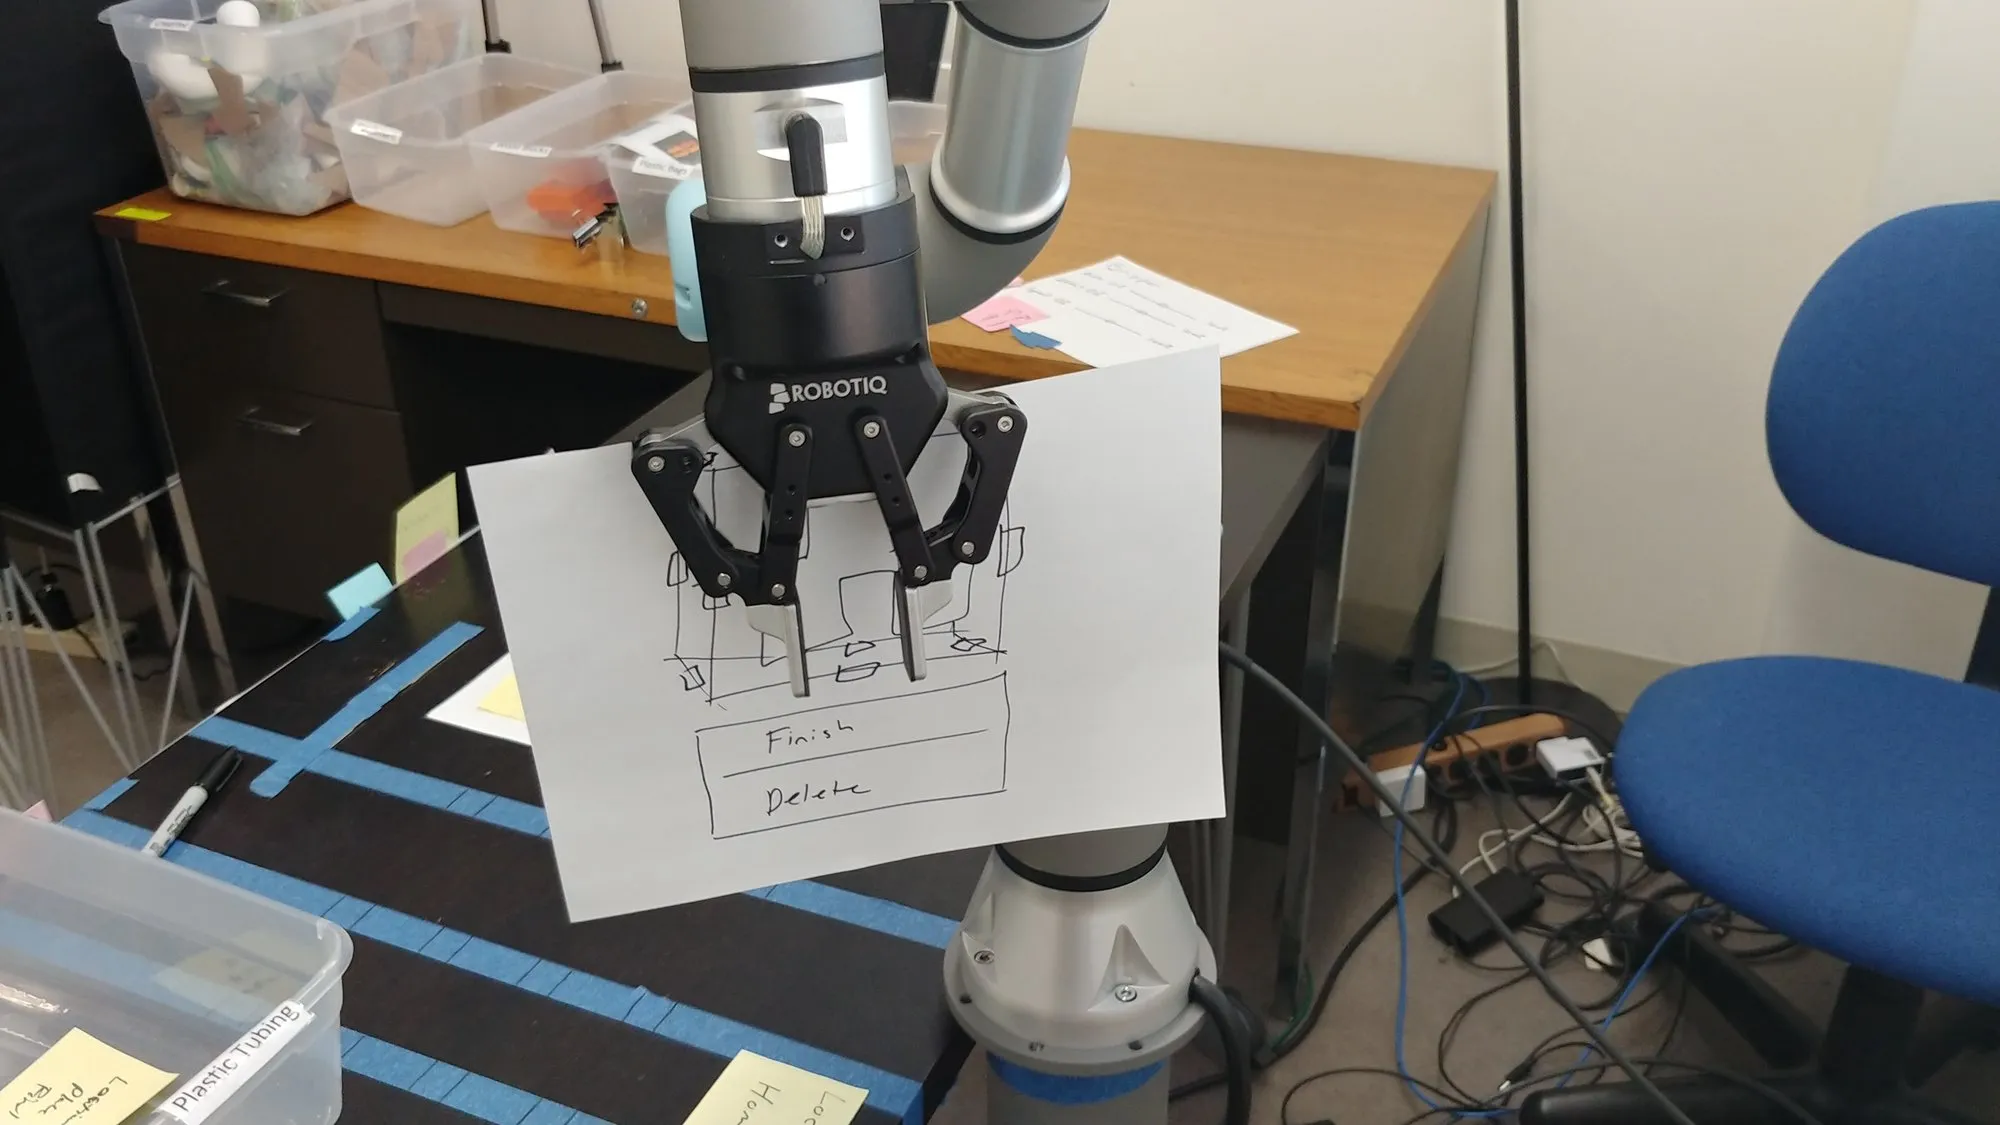
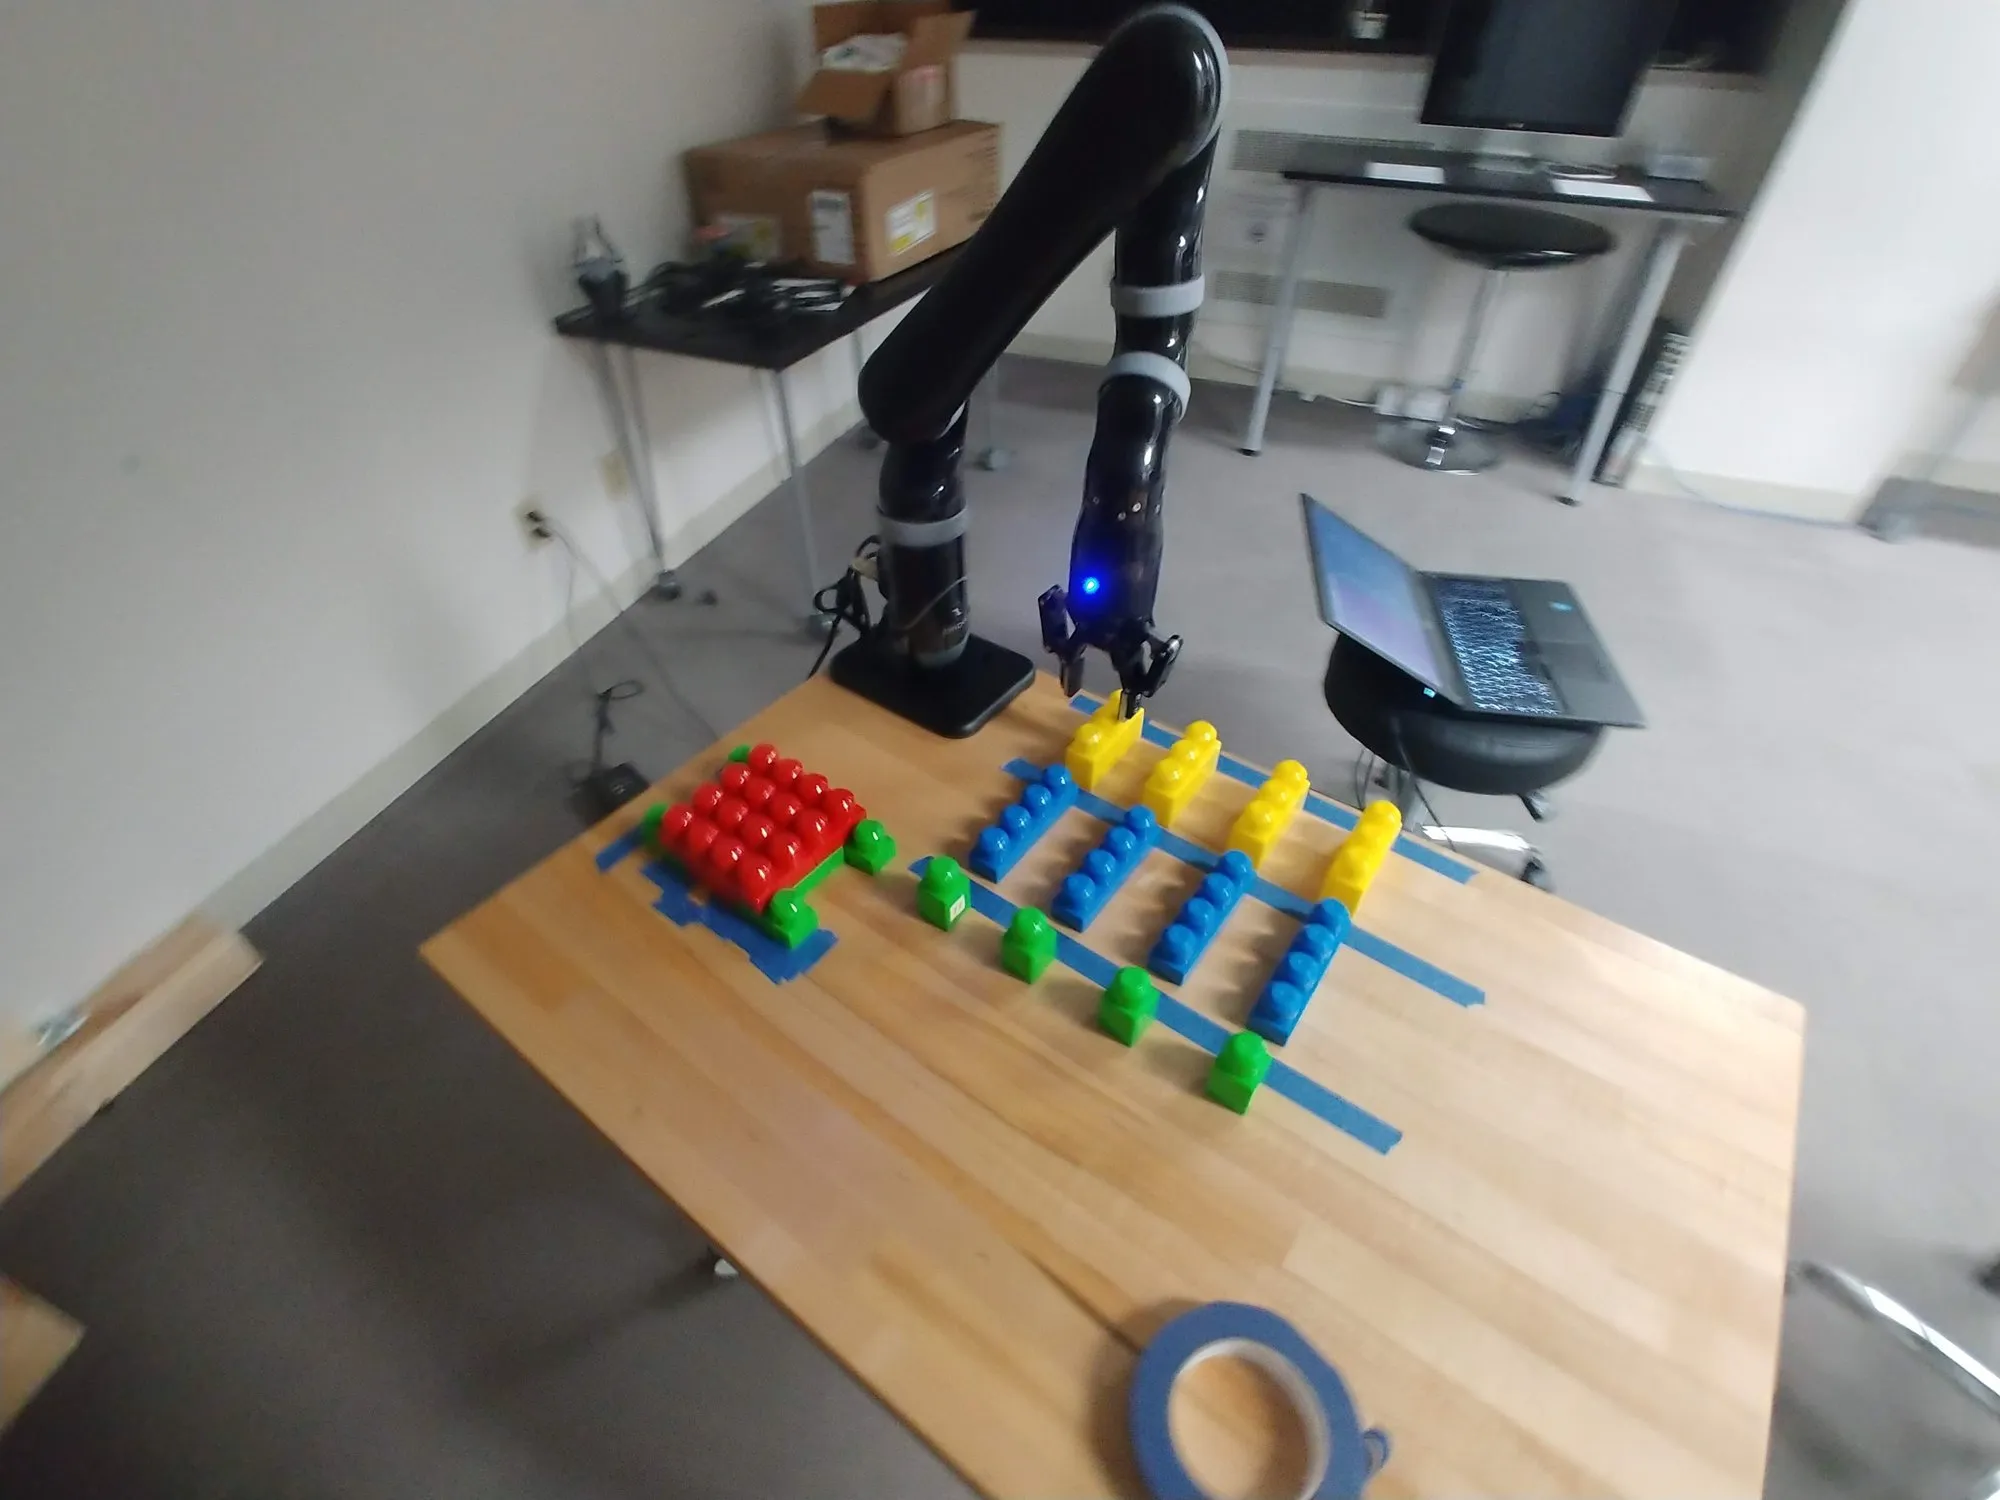
I started my Master's in Computer Science at UW-Madison in the fall of 2018 and graduated in the spring of 2021. I spent most of it in the People and Robots Lab under Dr. Bilge Mutlu, studying how…
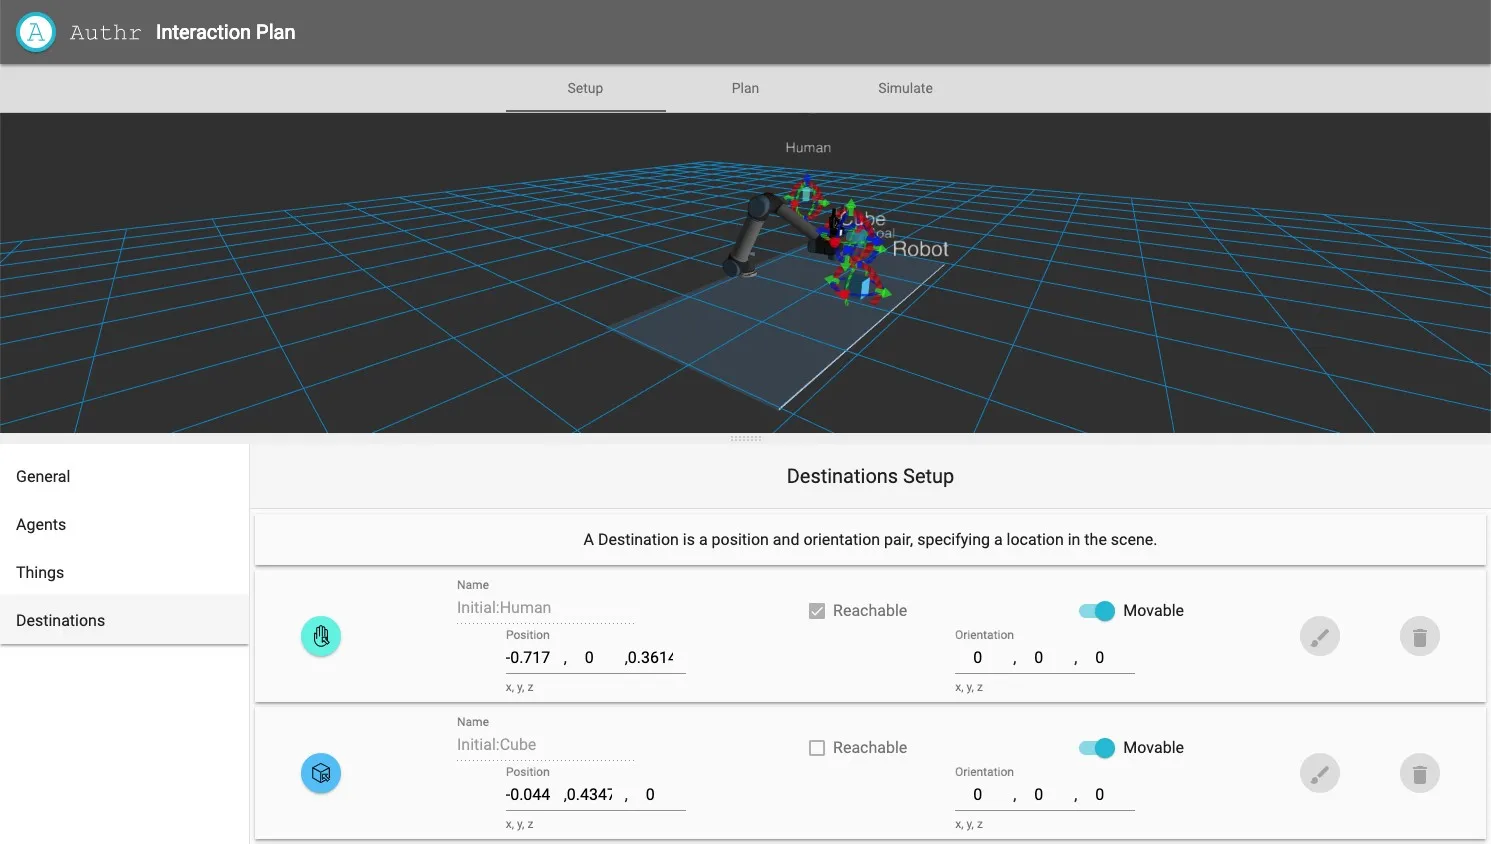
After the interaction paradigms studies had run (the paper was on simmer) and Authr was built (that paper was simmering too), one question was still hanging. Put a physical robot arm in front of an…
The UR5 is where I learned the Universal Robots stack. I had already played with MoveIt and ROS on the lab's Kinova Mico. Once I proved that I could handle a robot arm I was given access to the UR5…
The Kinova Mico is where I learned MoveIt and basic ROS. It was slow. It was janky. But I learned how to control an arm, which was pretty cool. The nice thing about the Kinova from an HCI perspective…
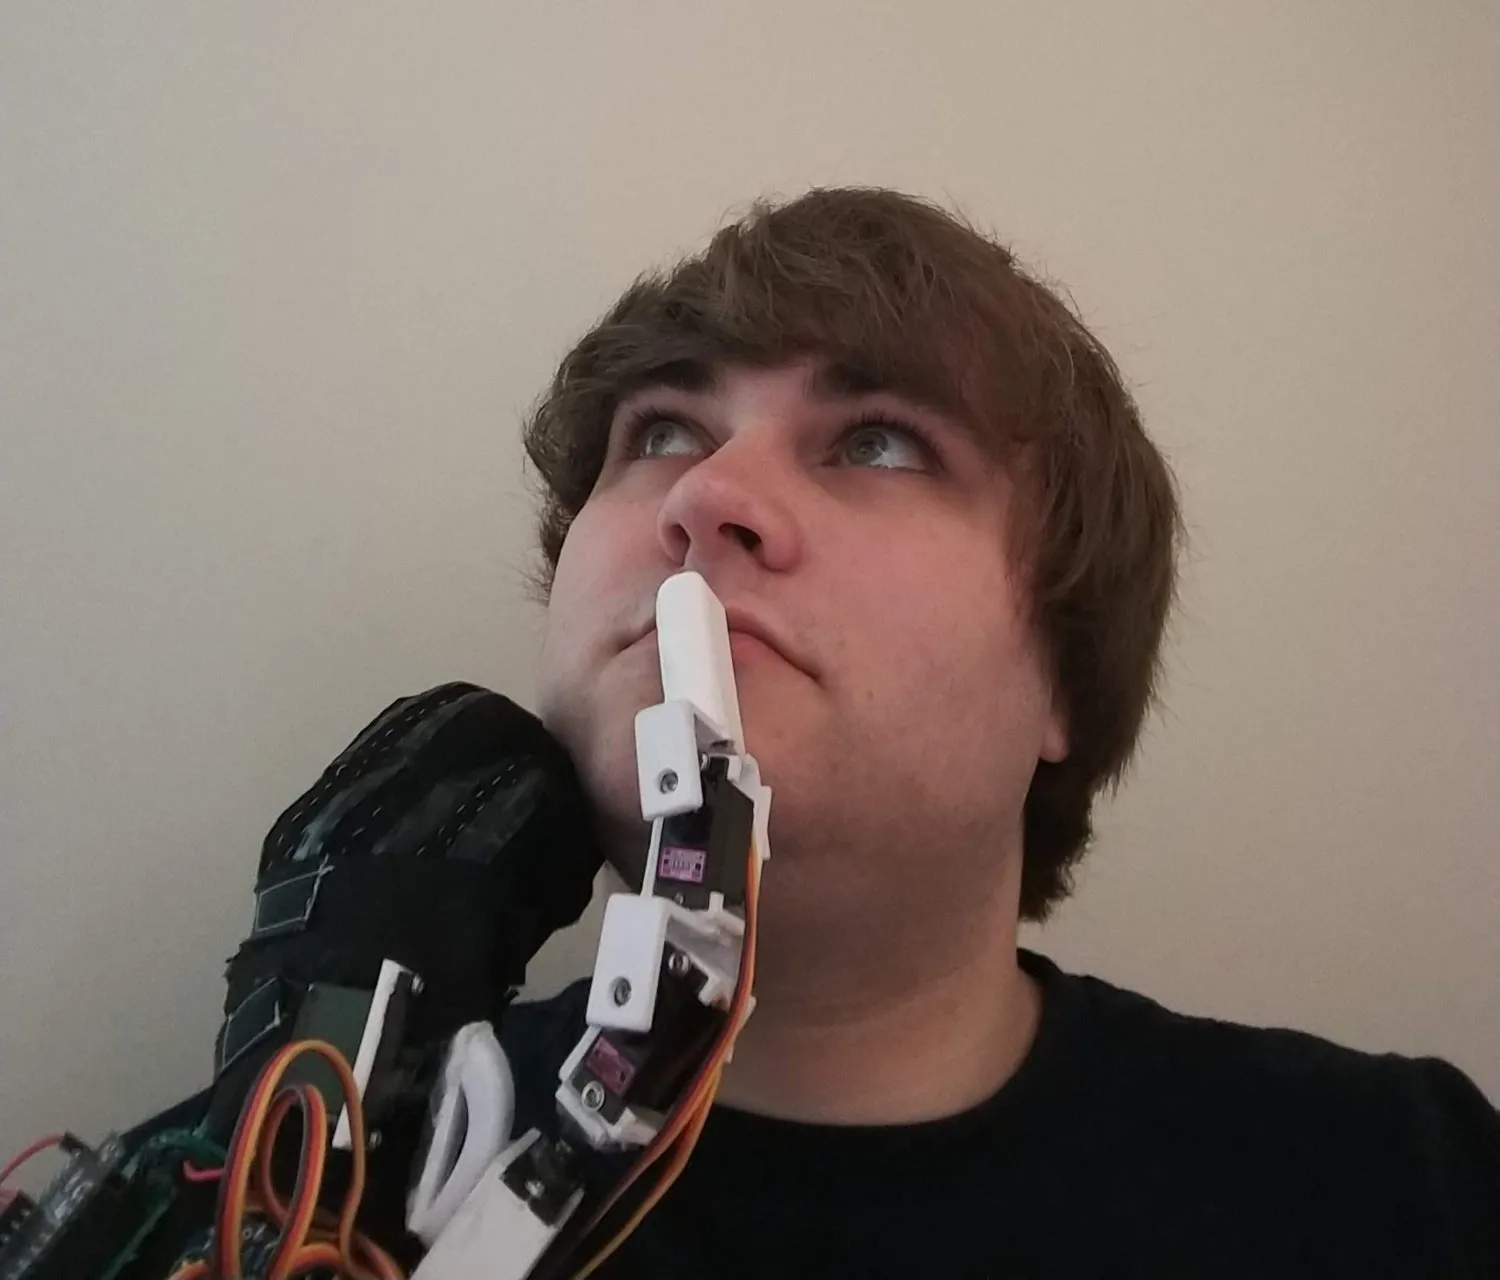
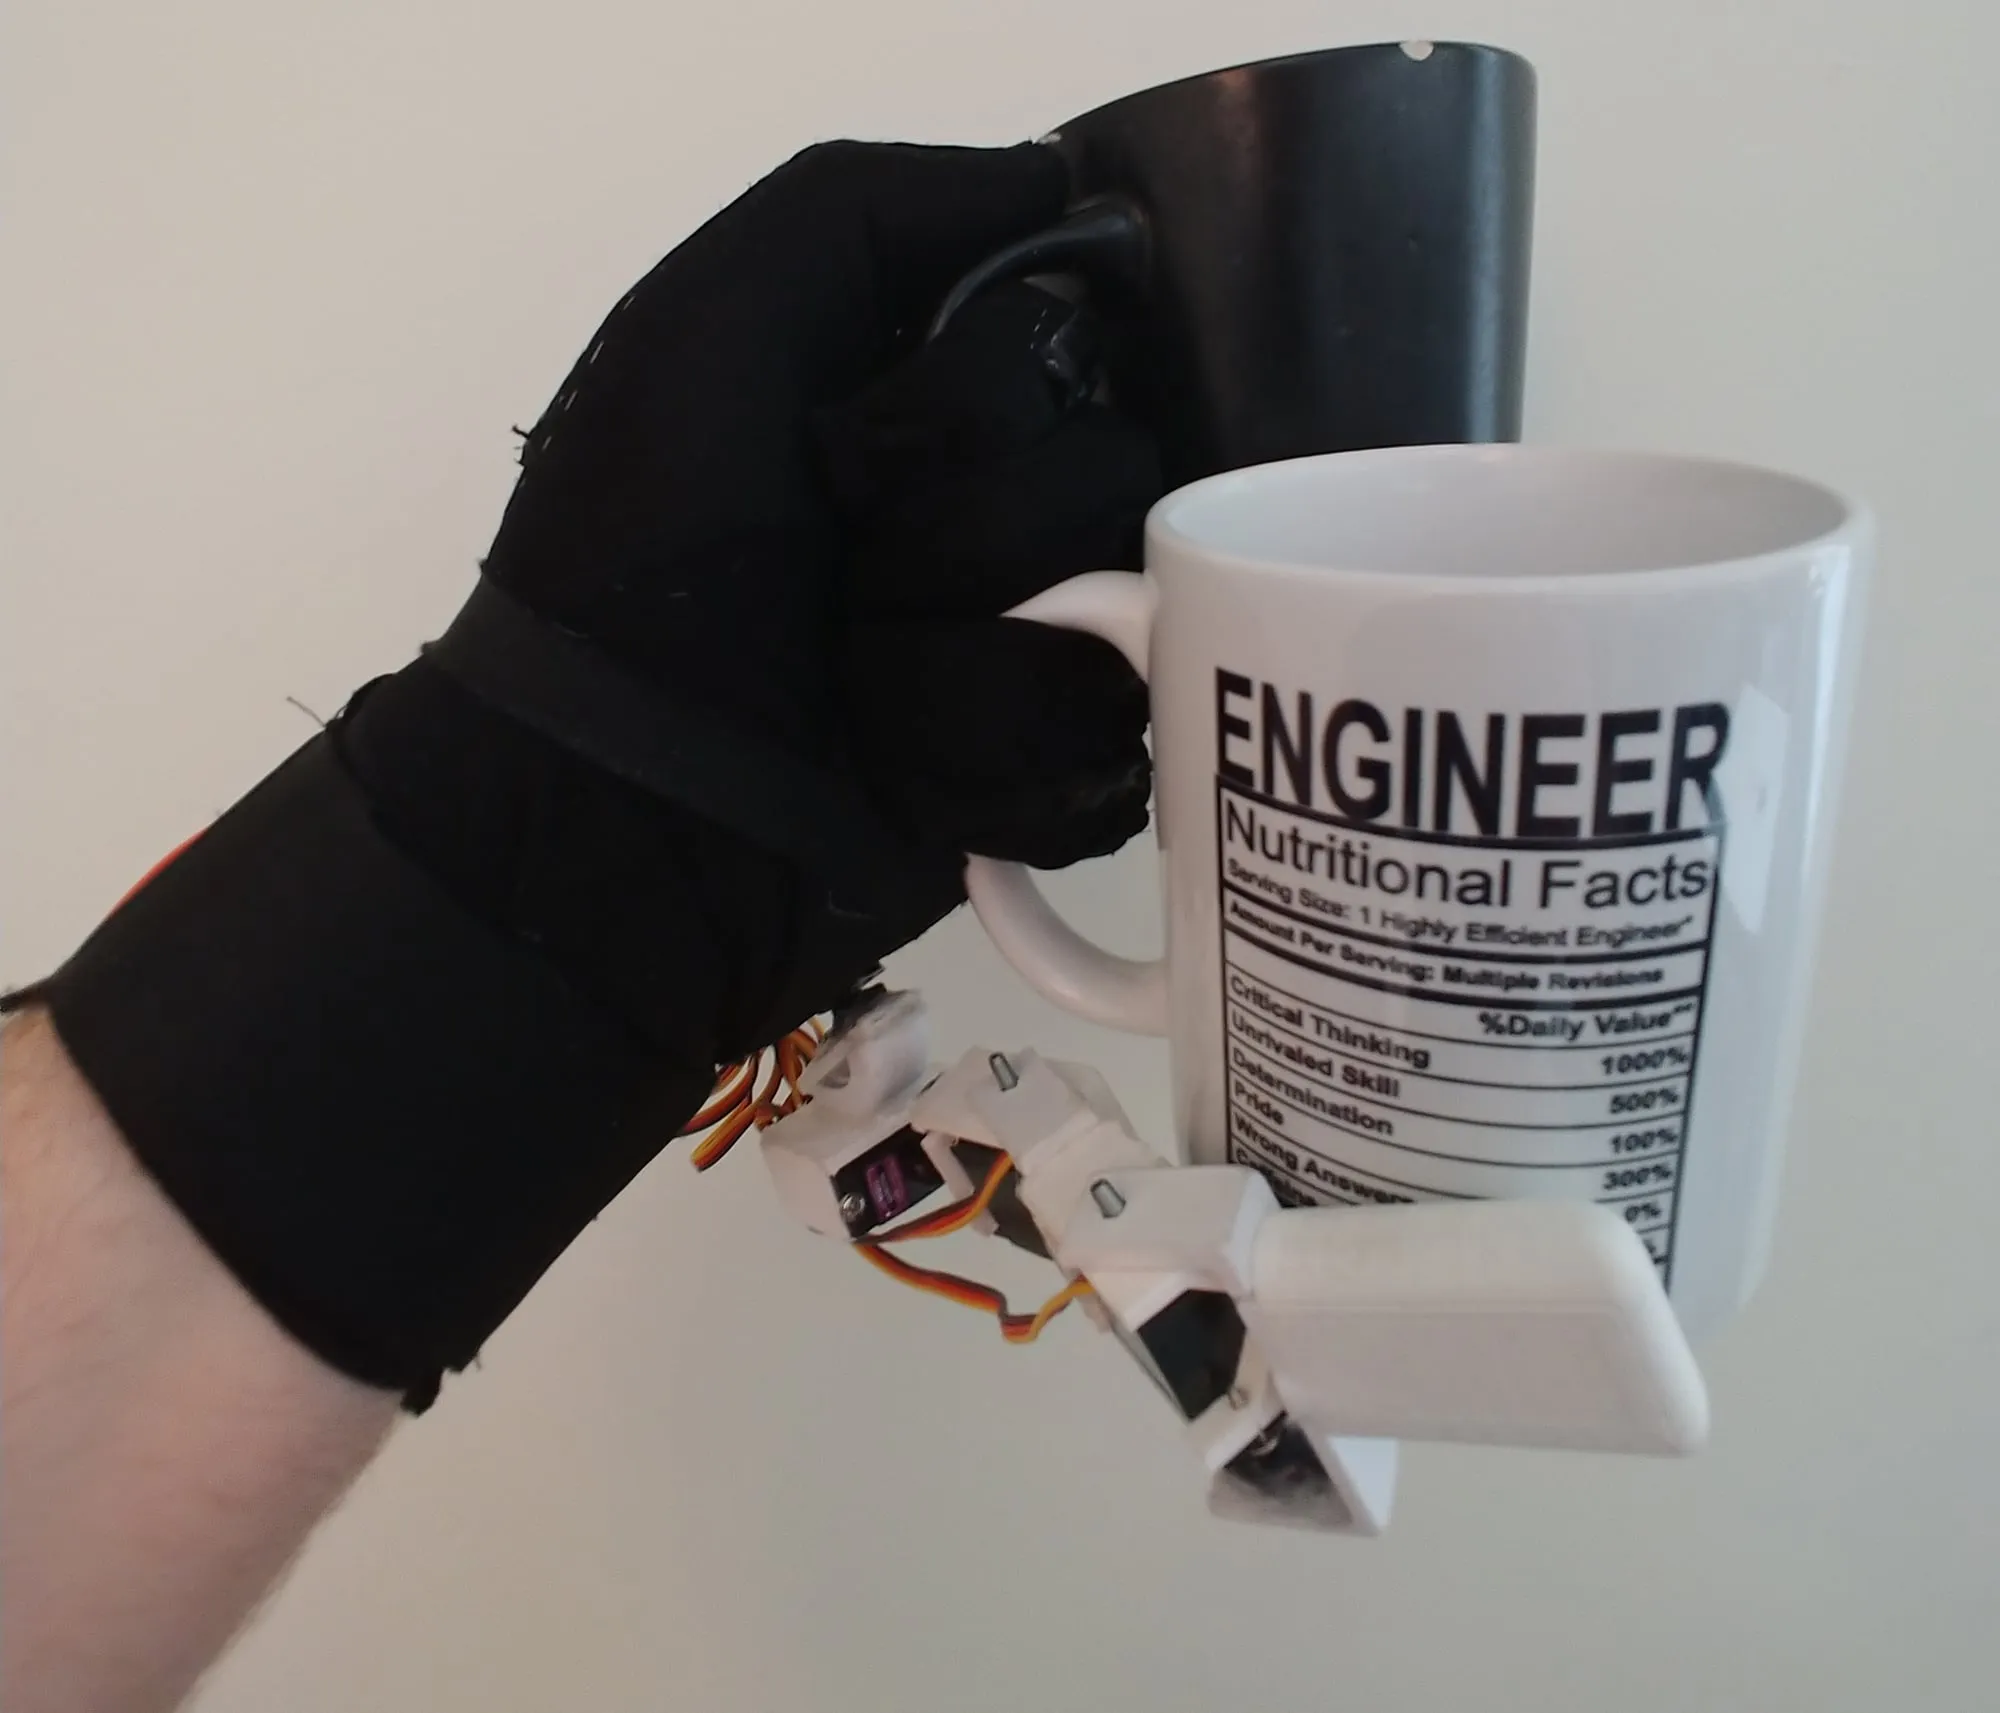
TL;DR: In 2019 I built a robotic sixth finger, named it after a Hungarian shaman, and then, during debugging, put it inside a plastic box because I had decided it was trying to get away from me. I…
Táltos is the shaman of Hungarian mythology, and one of the traits that supposedly marked someone as a táltos was being born with a physical abnormality, like an extra finger. So a Táltos-oid is a…
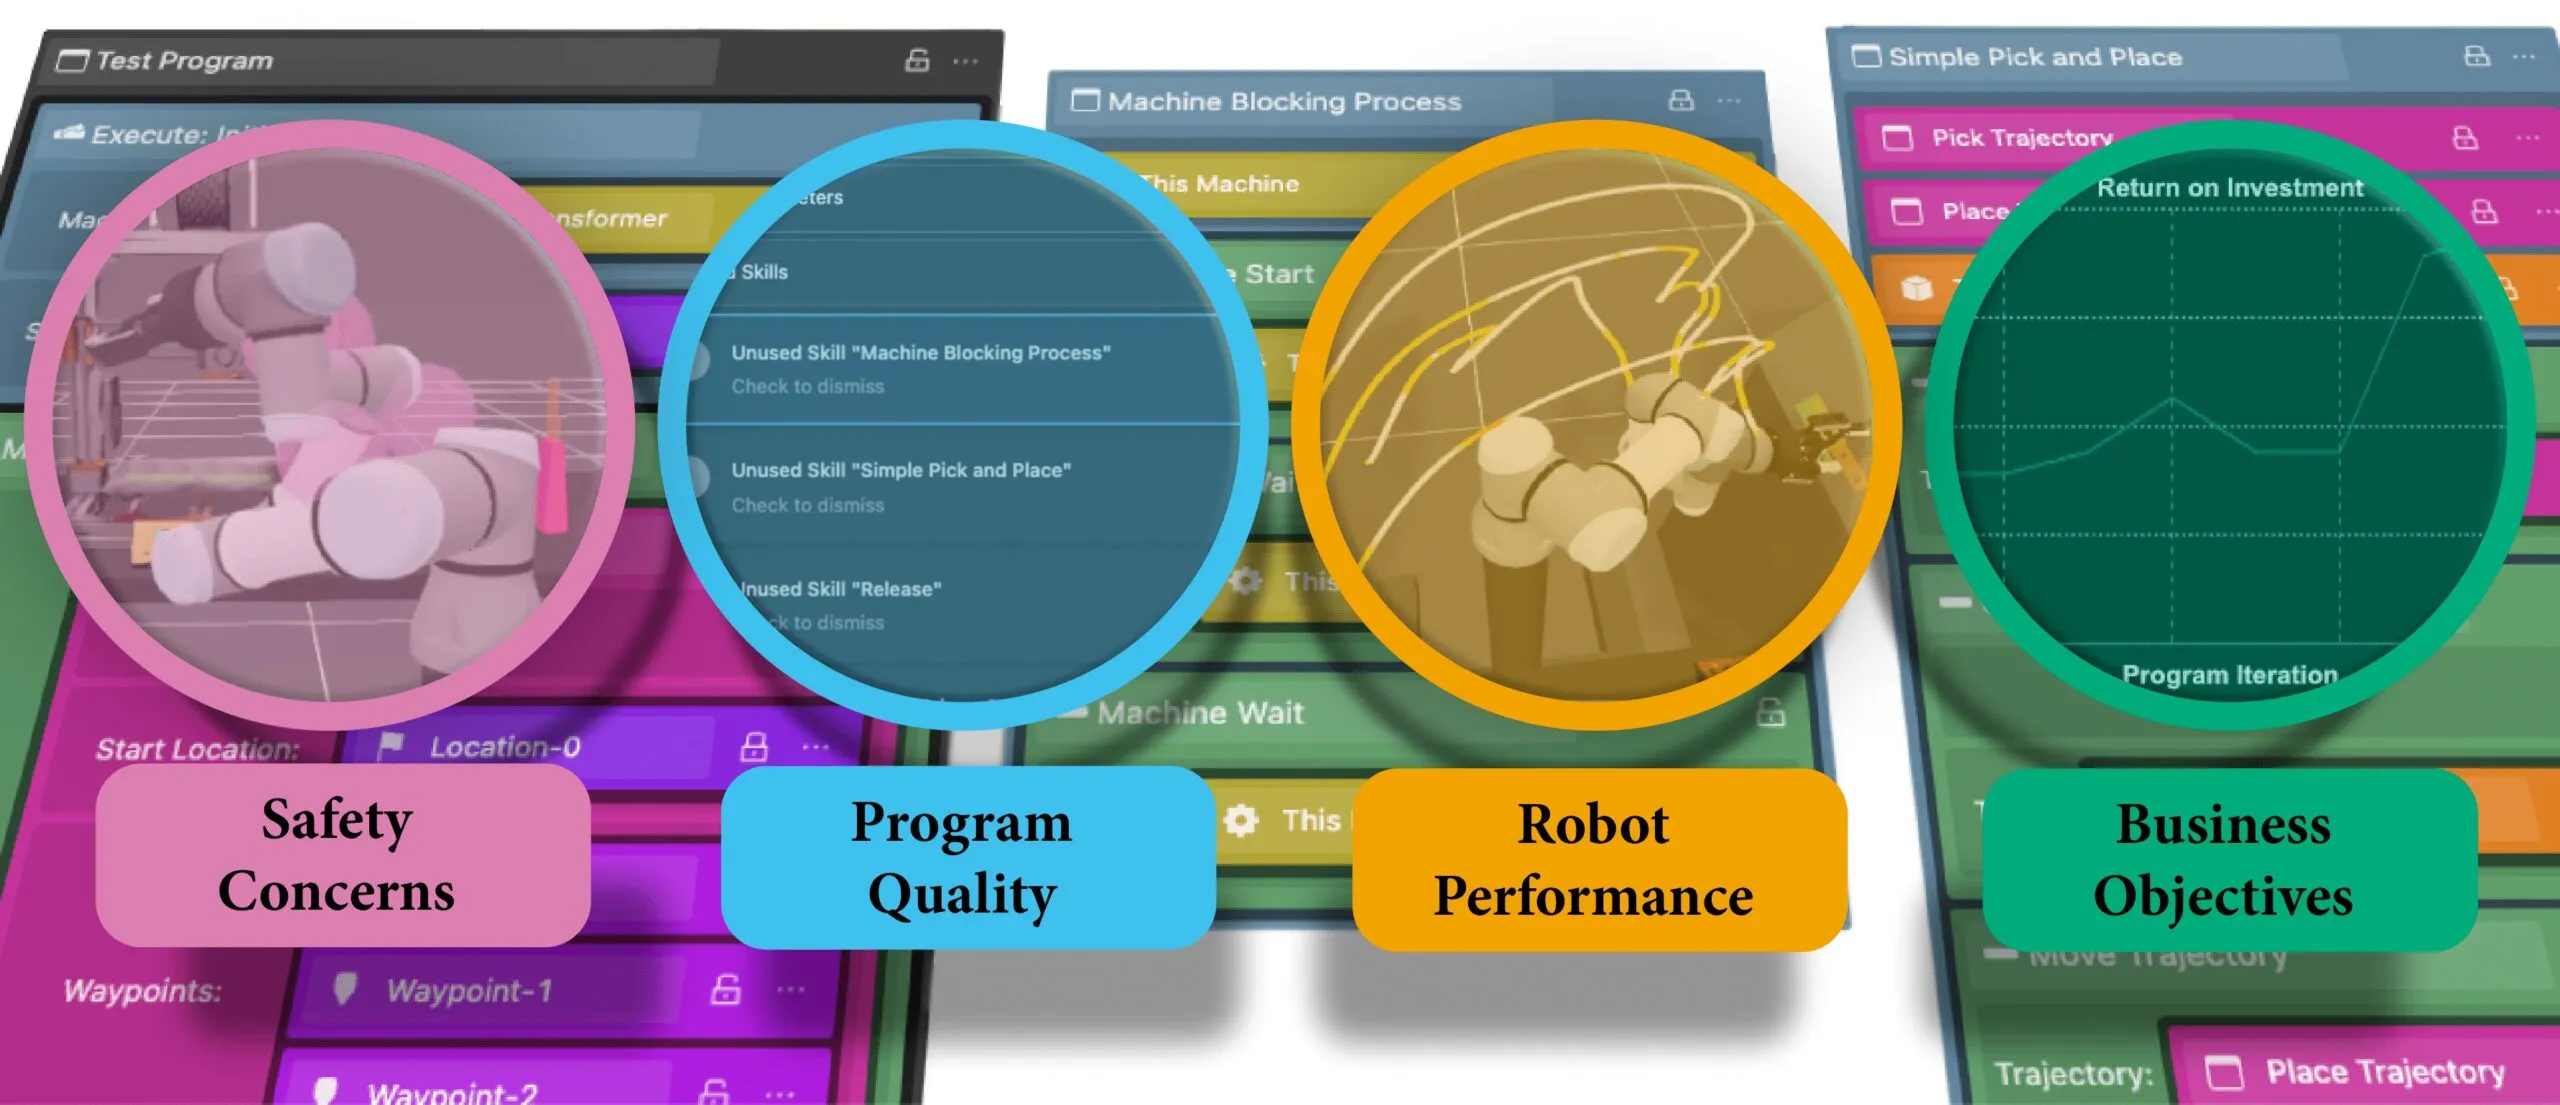
A cobot on a factory floor is only as good as the person programming it. The people who are good at that have been doing it for years, and most operators are not those people. There is a persistent…
Most manufacturing work was designed for a pair of human hands. Put a cobot on the line and someone has to take that work apart and decide which pieces go to the robot and which stay with the person…
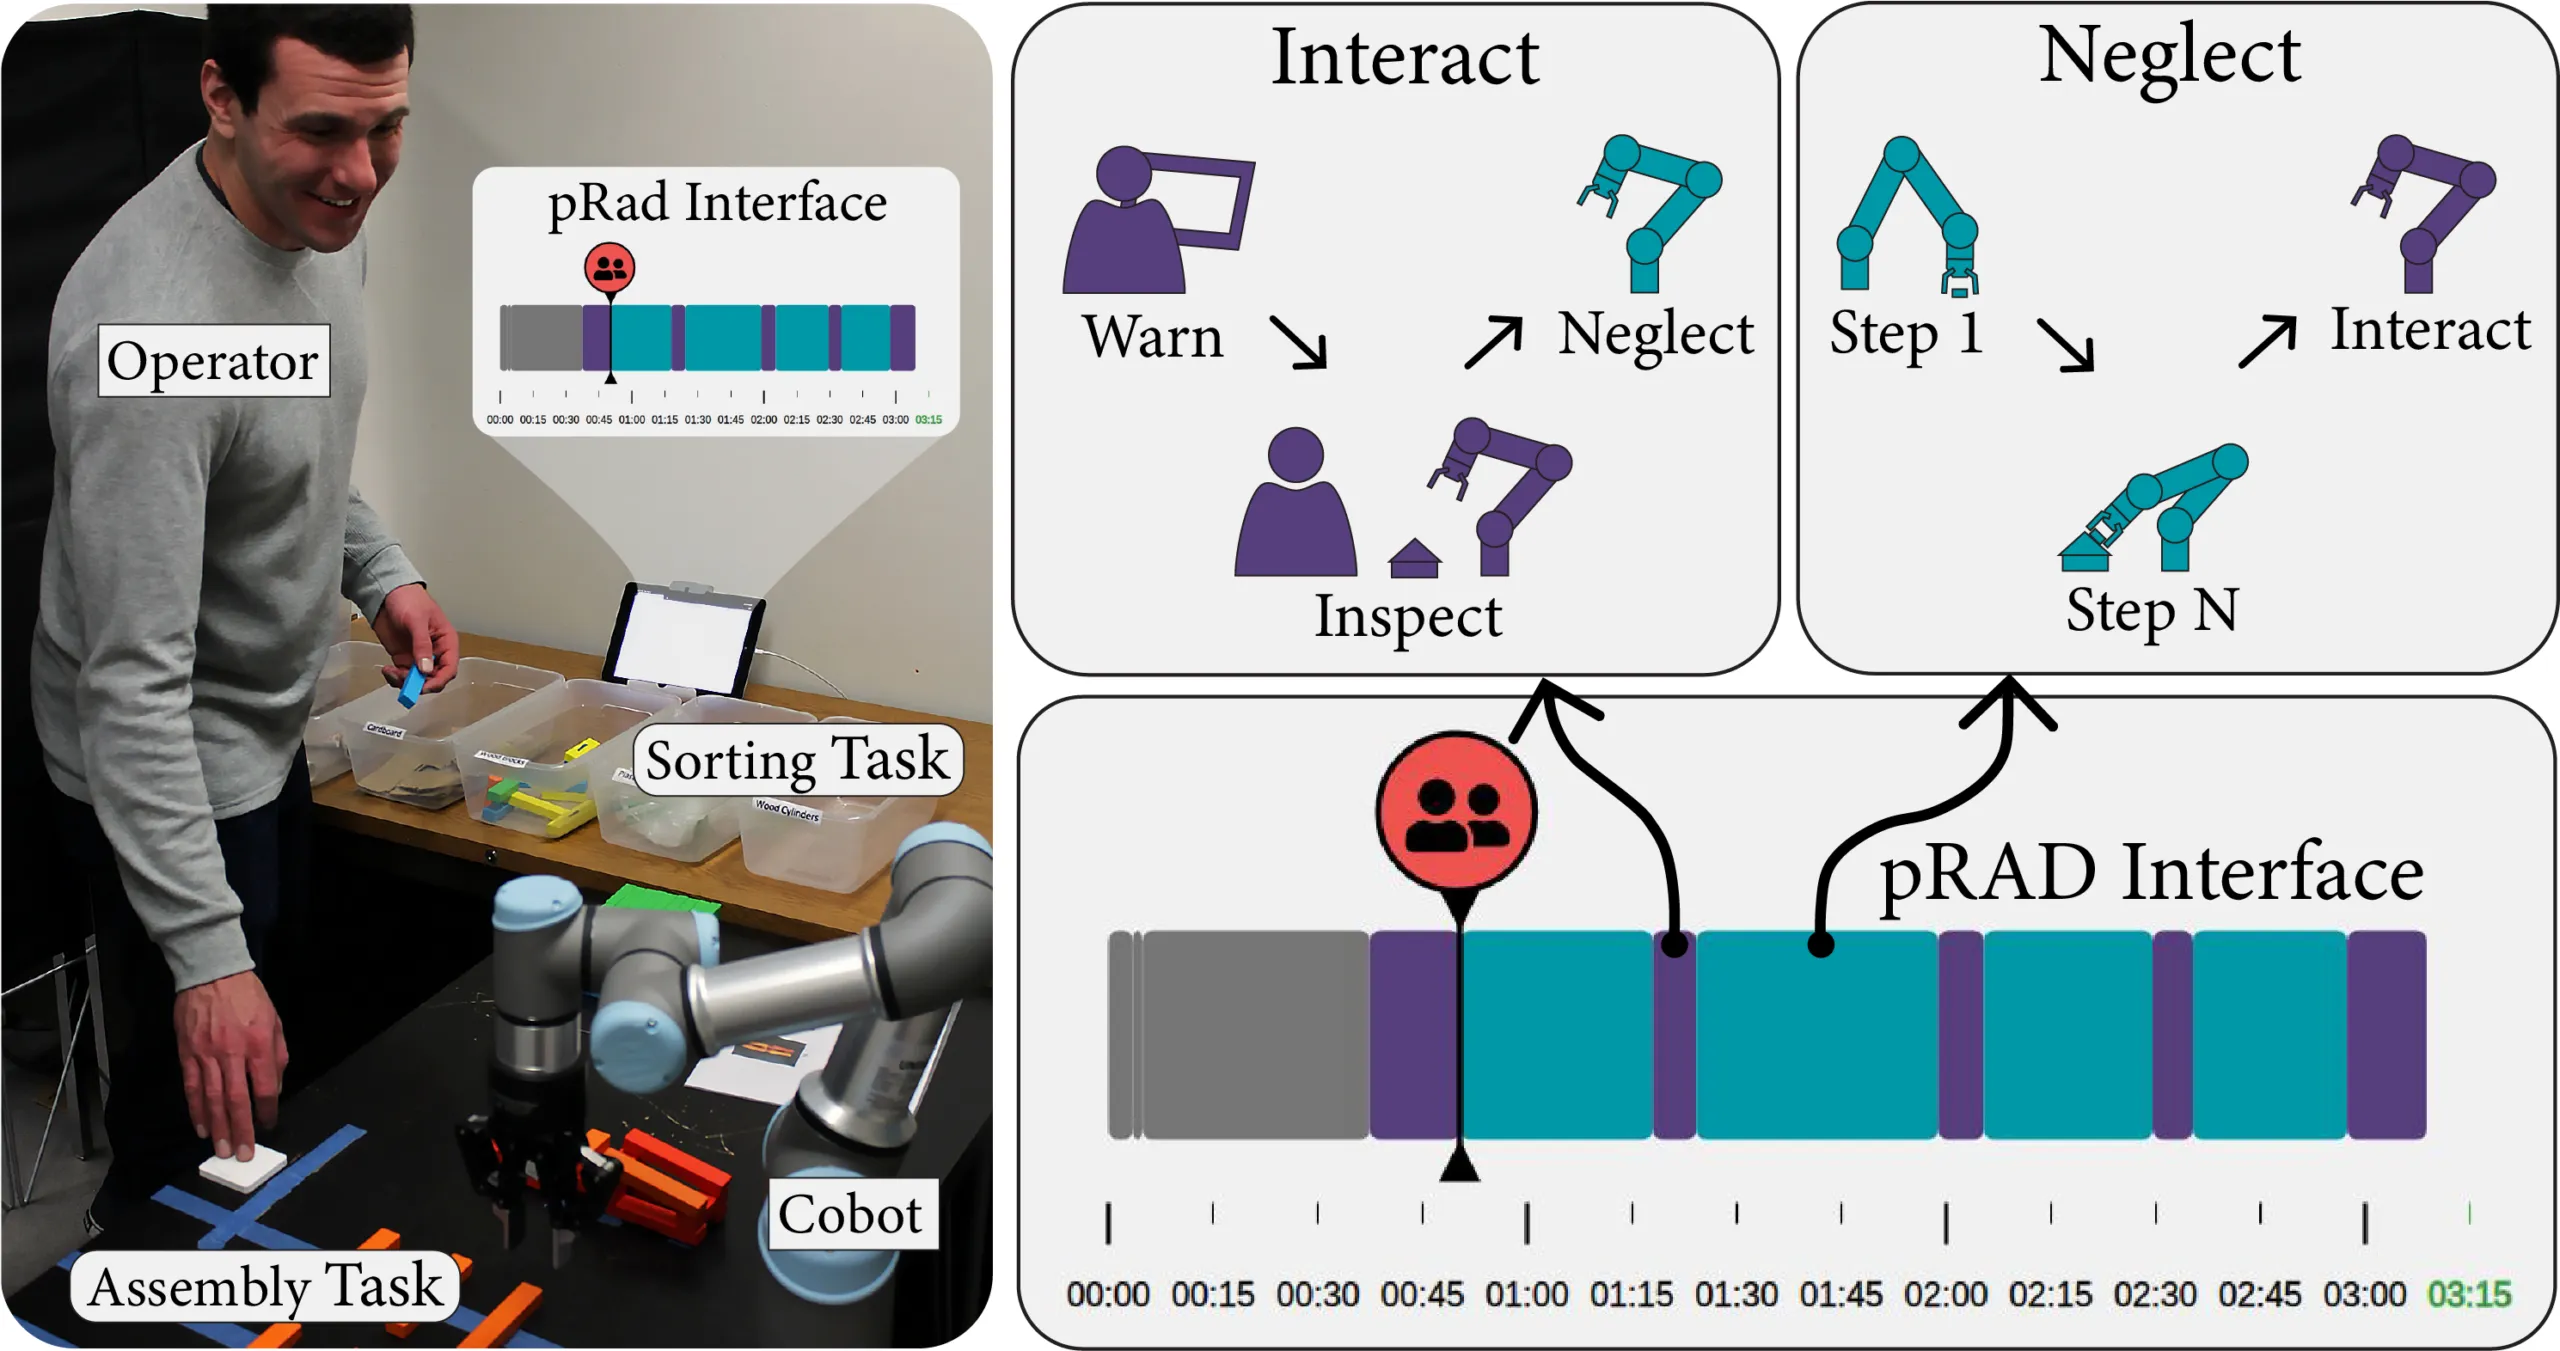
Working next to a cobot means sharing a task with a machine that runs on its own for a while and then needs you. The robot’s half takes care of itself. The hard part is guessing when your half is…
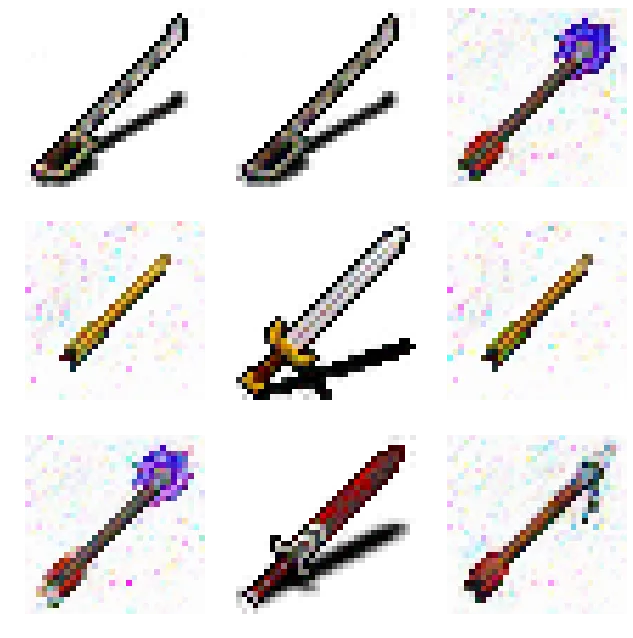
Back in Fall 2018, I took CS 534 (Computational Photography) at UW-Madison. The term project was open-ended, so naturally my team and I decided to see if we could get a neural network to generate…
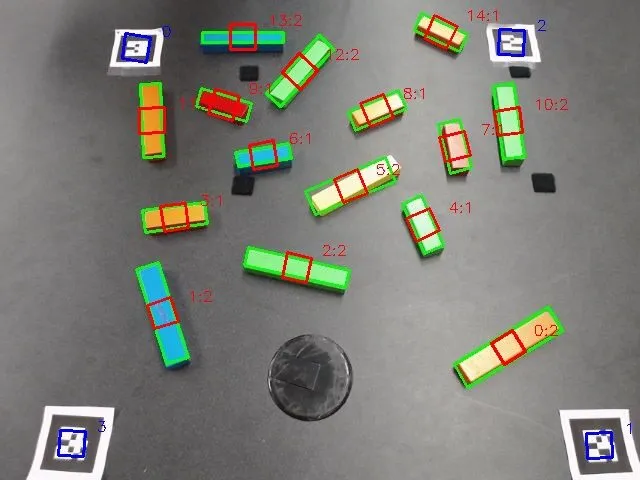
When you’re working on human-robot interaction research, there’s a surprisingly mundane problem that keeps showing up. The robot needs to know where things are. Specifically, in our case, the robot…
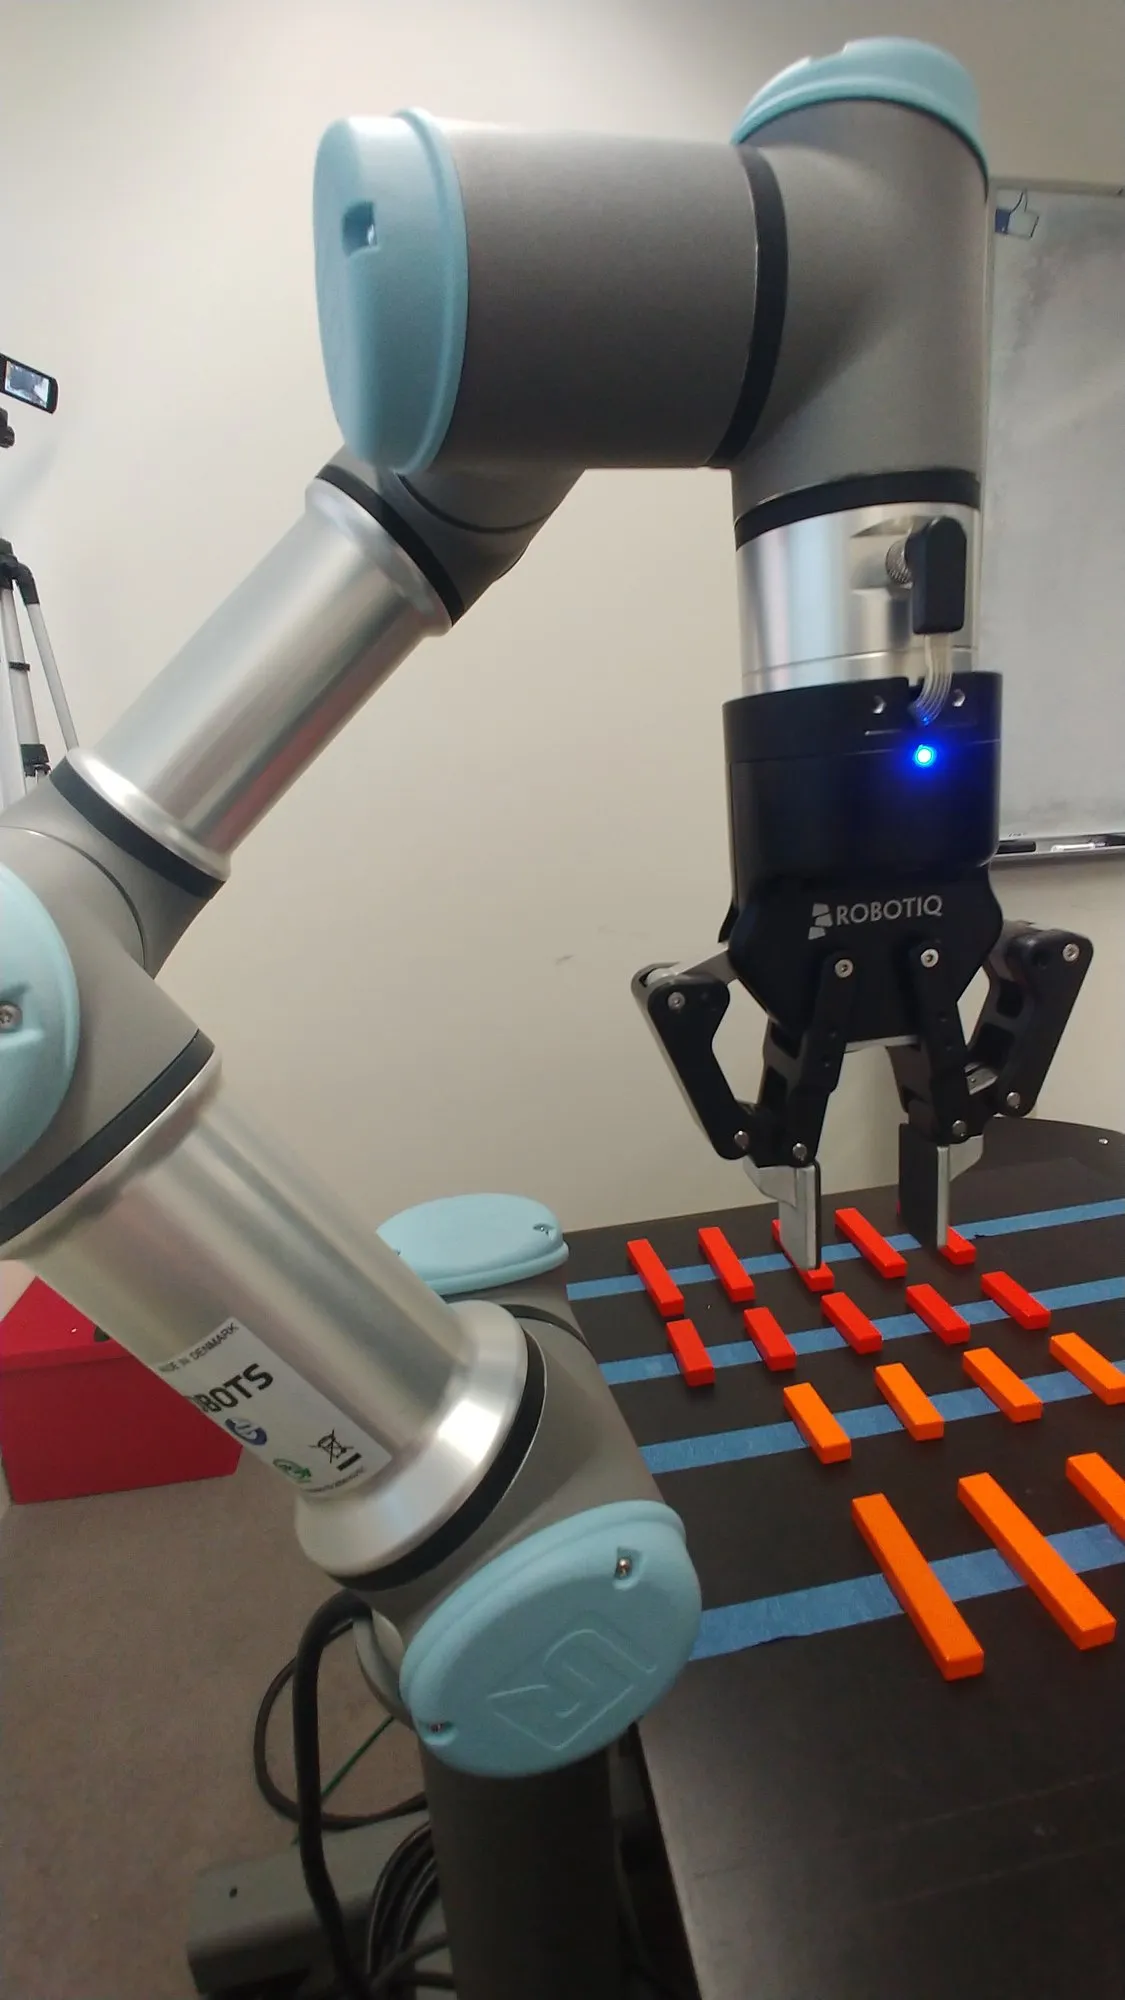
During my Master’s in Computer Science at UW-Madison, I spent most of my time in the People and Robots Lab working on human-robot interaction research under Dr. Bilge Mutlu. The lab had a UR3e cobot…
I found a 2D WebGL fluid simulation on GitHub’s trending page one Friday afternoon and lost about twenty minutes clicking around the canvas watching colors swirl. I forgot what I was actually doing…
This was a small project right at the start of COVID-19, where I needed two Universal Robots UR3e robot arms under ROS control. It was early lockdown, so there was no way I was getting into the lab…